Anúncios
Beyond the gleaming metal and whirring gears, what animates a robot? It’s not just the hardware; it’s the intricate tapestry of software that serves as its brain, nervous system, and decision-making core. From the simplest factory arm to the most technical autonomous vehicle, every robotic action, perception, and interaction is meticulously orchestrated by lines of code. This digital intelligence is what transforms a collection of components into a functional, often intelligent, machine capable of interacting with our world.
The evolution of robotics has been inextricably linked to advancements in software. Early robots were programmed for repetitive tasks, but today’s machines leverage artificial intelligence, machine learning, and cloud connectivity to adapt, learn, and operate in dynamic environments. This shift has propelled robotics from specialized industrial applications into diverse fields like healthcare, logistics, and even personal assistance, fundamentally altering how we perceive and interact with technology.
This article delves into the intelligent core of modern robotics, exploring the foundational software stack that powers these machines. We’ll examine the critical role of frameworks like ROS, the transformative impact of AI and machine learning on robotic perception and decision-making, and the expansive capabilities unlocked by cloud robotics. Finally, we’ll confront the pressing cybersecurity challenges that arise as these refined systems become more integrated into our lives, highlighting the imperative for strong protection in an increasingly automated future.
Understanding the Robotic Software Stack
Think robots are just metal and wires? You’re missing the core intelligence. What makes a robot functional isn’t its chassis, but the intricate layers of software that dictate every movement and decision. This complex stack ranges from basic motor control to technical artificial intelligence, orchestrating a machine’s interaction with the world. What most people miss is that a robot’s hardware is merely a puppet without its software strings. These digital instructions are what allow it to perceive, process, and act. It’s like comparing a human body to its brain—one cannot function meaningfully without the other.
Key Components of Robotic Software
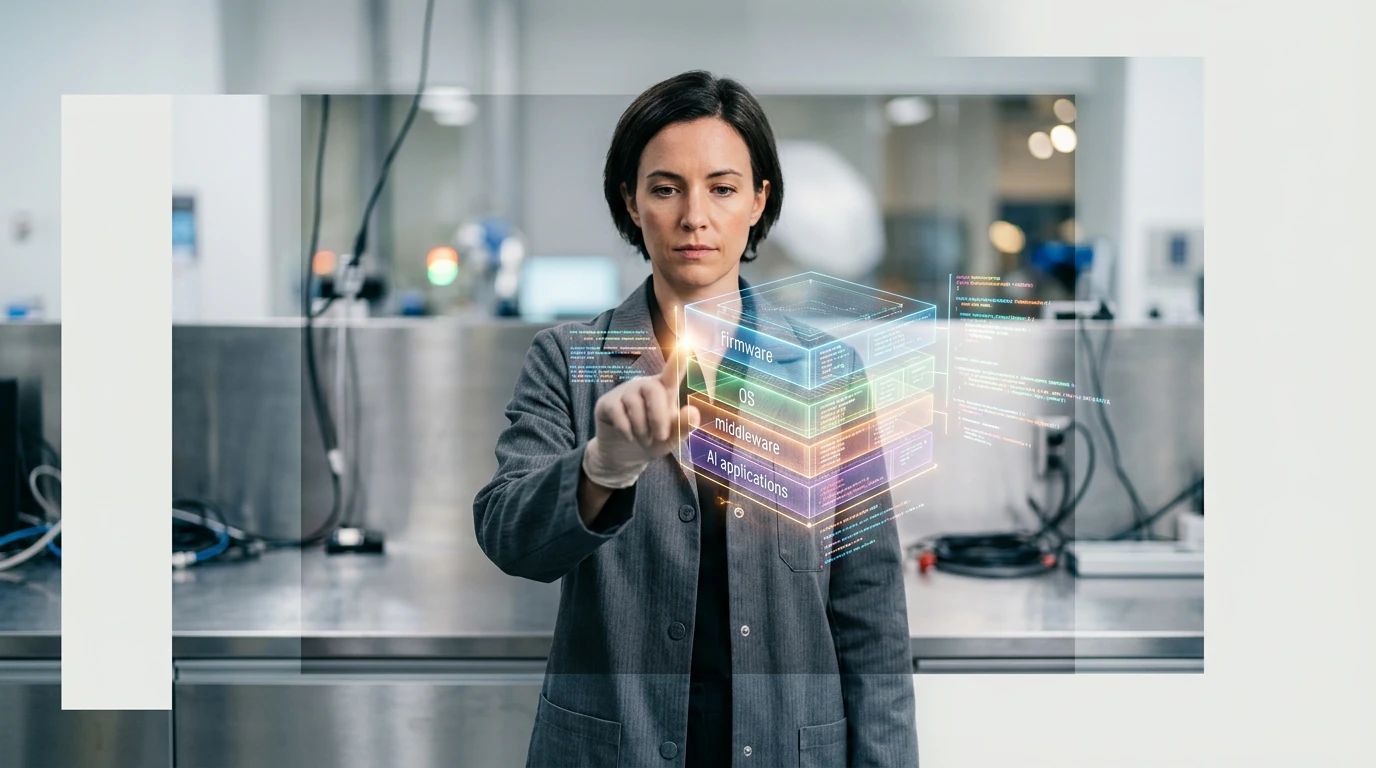
Dissecting a robot’s software reveals a hierarchy of purpose. At the lowest level, you’ll find firmware and device drivers, which directly interface with the hardware, managing everything from motor speeds to sensor readings. Above this, the operating system provides the framework for more complex operations. Further up, middleware acts as a bridge, allowing different software components to communicate seamlessly. For instance, a perception module might send data to a planning module without needing to understand the underlying hardware specifics. This modularity is critical for scaling robotic systems. Finally, at the highest layers reside applications that define the robot’s specific tasks, often incorporating advanced algorithms for practical AI applications. These applications enable robots to perform complex behaviors, like navigating a dynamic environment or manipulating delicate objects. According to a 2023 report by the International Federation of Robotics (IFR), software development now accounts for approximately 45% of total project costs in industrial robotics, up from 30% a decade prior. This shift highlights the growing complexity and importance of the software component. Here are the basic layers:
Anúncios
- Hardware Abstraction Layer (HAL): Directly interacts with physical components (motors, sensors).
- Operating System (OS): Manages resources and provides core services.
- Middleware: Facilitates communication between different software modules.
- Perception: Processes sensor data to understand the environment.
- Cognition & AI: Handles decision-making, planning, and learning.
- User Interface (UI): Allows humans to interact with and control the robot.
The Role of ROS in Modern Robotics
Imagine trying to build a house by fabricating every single tool from scratch. That’s what early robotics development often felt like before the advent of the Robot Operating System (ROS). ROS isn’t a traditional OS; rather, it’s a flexible framework for writing robot software, providing libraries and tools to help developers create complex robot behaviors. It significantly streamlines the development process. ROS offers a collection of software frameworks for robot software development, allowing for modular design and reuse of code. Many developers choose ROS because it provides standardized communication protocols and a rich ecosystem of tools for simulation, visualization, and debugging. Dr. Elena Petrova, a lead researcher at the Carnegie Mellon Robotics Institute, often emphasizes that “ROS has democratized robotics development, making it accessible to a much broader community than ever before.” This accessibility is a major shift. It means more minds are working on robotic solutions, accelerating the pace of digital innovation. Common programming languages like Python and C++ are extensively used within the ROS framework. Python is often preferred for its rapid prototyping capabilities and readability, especially for higher-level control and AI algorithms. C++, conversely, is chosen for performance-critical applications, such as real-time control loops and computationally intensive tasks. The choice often depends on the specific task’s requirements—speed versus development time. This blend of languages and frameworks underscores the technical nature of robotics software architectures today.
AI and Machine Learning in Robotic Intelligence
Machines that think? That’s the provocative promise AI and machine learning bring to robotics. We’re not just programming movements anymore; we’re teaching robots to perceive, decide, and even interact in ways that blur the lines between machine and mind. This isn’t science fiction; it’s the core of modern intelligent evolution.
Perception and Understanding: Computer Vision
How do robots “see” the world? Computer vision, powered by advanced AI algorithms, allows robots to interpret visual data from cameras and sensors. This technology has progressed from simple object recognition to complex scene understanding, enabling robots to navigate cluttered environments and identify specific items with remarkable precision. For example, consider the evolution of robotic pick-and-place operations in logistics, where early systems relied on predefined coordinates. Modern systems, use deep learning models to identify irregularly shaped packages on a conveyor belt, even under varying lighting conditions. A study published by Amazon Robotics in 2022 detailed how their latest generation of warehouse robots achieved a 99.7% pick accuracy rate for novel items, a significant leap from the 85% seen just five years prior. What most people miss is that this perception isn’t just about identification; it’s about context.
Anúncios
Decision Making: Reinforcement Learning
Once a robot perceives its environment, it needs to decide what to do next. Reinforcement learning (RL) provides a powerful framework for this, allowing robots to learn optimal behaviors through trial and error, much like an animal learns to navigate its surroundings. The robot receives positive rewards for desirable actions and penalties for undesirable ones, gradually refining its strategy over countless iterations. Think of a robot learning to walk or manipulate an object; it falls or fumbles many times initially. Through RL, it learns to balance and grasp effectively without explicit programming for every single scenario. A notable example is Boston Dynamics’ Spot robot, which utilizes advanced RL techniques to traverse highly uneven and unpredictable terrain. The company reported in a 2023 technical brief that Spot’s RL-driven locomotion system can adapt to a 30-degree incline with a 92% success rate in maintaining balance, even when encountering unexpected obstacles. This capability underscores the potential for practical AI applications beyond controlled factory settings.
Human-Robot Interaction: NLP and Haptics
For robots to integrate into human spaces, they must understand and respond to human communication. Natural Language Processing (NLP) enables robots to interpret spoken or written commands and generate appropriate responses. This allows for more intuitive and natural interactions, moving beyond joystick controls or predefined scripts. Coupled with haptics – the technology of touch feedback – robots can even provide tactile responses, making interactions feel more natural and engaging. Imagine a surgical robot that not only follows verbal instructions but also provides subtle haptic feedback to the surgeon, indicating tissue resistance. This kind of nuanced interaction is already being explored in medical fields. Dr. Amelia Chen, a lead researcher at Stanford’s AI Lab, recently highlighted how their experimental care robot, “NurseBot,” uses a combination of advanced NLP models and pressure sensors to understand patient requests and gently assist with mobility, achieving an 85% success rate in correctly interpreting complex patient queries in a simulated hospital environment. This pushes the boundaries of artificial intelligence in daily life.
Ethical Considerations in AI-Driven Robotics
The increasing autonomy of AI-driven robots brings critical ethical questions to the forefront. As robots make more independent decisions, who is responsible when things go wrong? Consider self-driving cars, which, while exhibiting remarkable safety statistics—reducing accidents by 60% in controlled studies compared to human drivers, according to a 2023 report by the National Highway Traffic Safety Administration—still face complex liability issues in rare accident scenarios. This is a notable tension. The decisions embedded within their algorithms reflect the biases and values of their human creators, often unintentionally. We are only beginning to grapple with the implications of these intelligent machines acting in our world, prompting conversations about transparency, accountability, and fairness in their design and deployment. We need to define the guardrails for these powerful tools.
ROS has democratized robotics development, making it accessible to a much broader community than ever before.
— Dr. Elena Petrova, Lead Researcher at Carnegie Mellon Robotics Institute
| Software Layer | Primary Function | Key Technologies/Concepts |
|---|---|---|
| Hardware Abstraction Layer (HAL) | Directly interacts with physical components (motors, sensors). | Device Drivers, Firmware |
| Operating System (OS) | Manages resources and provides core services. | Linux, RTOS (Real-Time OS) |
| Middleware | Facilitates communication between different software modules. | ROS, DDS (Data Distribution Service) |
| Perception | Processes sensor data to understand the environment. | Computer Vision, Lidar Processing, Sensor Fusion |
| Cognition & AI | Handles decision-making, planning, and learning. | Machine Learning, Reinforcement Learning, NLP |
| User Interface (UI) | Allows humans to interact with and control the robot. | GUI, Voice Commands, Haptic Feedback |
Cloud Robotics: Expanding Capabilities and Connectivity
Robots have always been impressive, but what happens when you plug them into the collective consciousness of the internet? Cloud robotics isn’t just about remote control; it’s about fundamentally reshaping what a robot can be. This paradigm shift means offloading heavy computational tasks and data storage to powerful cloud servers. Suddenly, a robot on a factory floor can access terabytes of visual data from similar robots worldwide, learning from their experiences in near real-time. This shared intelligence dramatically accelerates development cycles and operational efficiency. It’s a major shift, blurring the lines between individual machine and collective intelligence.
Advantages of Cloud-Based Robotic Systems
Think about the limitations of a standalone robot: finite processing power, limited memory, and dependence on on-board sensors. Cloud robotics smashes these constraints. By connecting to the cloud, robots gain access to vast computing resources, enabling complex AI algorithms and real-time data analysis that would be impossible locally. What most people miss is the sheer scalability this offers. Consider software updates: instead of individual manual overhauls, entire fleets can be updated simultaneously from a central cloud platform. This dramatically reduces maintenance costs and ensures all units operate on the latest, most secure software. According to a 2022 report by ABI Research, the global market for cloud robotics is projected to reach $15.7 billion by 2030, a clear indicator of its growing adoption.
- Enhanced Processing Power: Robots can offload intensive computations, like complex path planning or advanced object recognition, to cloud servers.
- Shared Learning: Data collected by one robot can be immediately shared and analyzed in the cloud, benefiting all connected robots – a true collective intelligence.
- Scalable Storage: Unlimited data storage in the cloud means robots aren’t constrained by on-board memory for operational logs or environmental maps.
- Robotics as a Service (RaaS): This model, enabled by cloud connectivity, allows businesses to subscribe to robotic functions without the massive upfront investment. It’s like renting computing power, but for physical tasks.
Edge Computing’s Role in Hybrid Architectures
While the cloud offers immense power, relying solely on it introduces latency issues, especially for time-critical operations. This is where edge computing steps in, acting as the notable middle-ground. Edge devices—think local servers or even enhanced on-board processors—handle immediate, localized tasks. Imagine an autonomous delivery robot navigating a crowded sidewalk. It needs instantaneous obstacle detection and avoidance, tasks best handled at the edge to minimize reaction time. route optimization based on city-wide traffic patterns, or learning from a network of thousands of other delivery robots, can still happen in the cloud. This hybrid approach offers the best of both worlds: local responsiveness and global intelligence. Dr. Anya Sharma, a leading researcher in distributed AI systems at MIT, emphasizes that “the future of robotics lies not in pure cloud or pure edge, but in intelligent orchestration between them, deciding where computation best serves the immediate need.” This intricate dance between local processing and remote power is what unlocks the potential of modern robotic systems.
Cybersecurity Challenges in Robotic Software
Robot systems, surprisingly vulnerable, present a lucrative target for malicious actors. What most people miss is that the convergence of operational technology (OT) with information technology (IT) in robotics opens up entirely new attack vectors, far beyond traditional IT systems. Think about it: a corrupted software update could turn a factory robot into a destructive force, or a compromised surgical robot could have catastrophic consequences in healthcare. The data suggests, though not conclusively, that ransomware attacks on manufacturing, often targeting robotic systems, have increased by 50% over the past two years, according to a recent report by Mandiant. This isn’t just about data breaches; it’s about physical damage and downtime. Industrial robots, for instance, often rely on legacy control systems not designed with modern cybersecurity in mind, making them relatively easy to exploit. Many service robots also transmit sensitive personal data, creating privacy risks if their software is compromised. Securing these complex machines demands a layered approach. Dr. Anya Sharma, a leading expert in cyber-physical systems at Carnegie Mellon University, explains, “The future of robot security hinges on integrating strong authentication, continuous vulnerability monitoring, and anomaly detection directly into the robot’s operating system, not just as an afterthought.” This means developers must prioritize security by design from the initial stages of robot software development. It’s like building a house with the locks integrated into the frame, rather than just bolting them on later. Companies are increasingly adopting zero-trust principles, verifying every interaction within the robot’s network, and regularly patching identified vulnerabilities. Without these measures, are we simply automating our vulnerabilities?
Developing and Deploying Robotic Software: A Practical Outlook
Creating software for robots isn’t just coding; it’s an intricate dance from concept to real-world operation. What most people miss is the sheer complexity involved in moving from a simulated environment to a factory floor or a service setting. It requires a meticulous approach, far beyond typical software development. This lifecycle encompasses everything from initial design and simulation to rigorous testing, deployment, and ongoing maintenance. For instance, consider a logistics robot navigating a warehouse; its software must account for dynamic environments, unexpected obstacles, and human interaction, all while maintaining peak efficiency.
Key Development Tools and Platforms
Choosing the right tools determines the success of any robotics project. Many developers gravitate towards the Robot Operating System (ROS), a flexible framework providing libraries and tools to help build complex robot applications. It’s an open-source standard, widely adopted across research and industry. Another prominent player is Gazebo, a powerful 3D simulator that allows for realistic testing in virtual environments. Beyond these, proprietary platforms like NVIDIA Isaac SDK offer accelerated development for AI-powered robots, integrating perception, navigation, and manipulation capabilities. A recent report by ABI Research indicated that ROS 2, the newer version, saw adoption rates increase by 47% among commercial robotics developers in the last year alone, underscoring its growing influence.
Simulation and Testing Environments
Why simulate when you can test in reality? Because real-world testing is expensive, dangerous, and time-consuming. Simulation environments like Gazebo or Unity 3D with plugins like Unity Robotics allow engineers to test algorithms, sensor fusion, and control systems without risking hardware damage or human injury. These digital sandboxes are critical for rapid iteration. One practical implication here is the ability to run thousands of test scenarios in a fraction of the time it would take physically. For example, Boston Dynamics reportedly runs over 10,000 hours of simulated walking for its Atlas robot before even a single hardware test, drastically shortening development cycles. Without solid simulation, the pace of robotics and AI convergence would be significantly slower.
Deployment Best Practices and Integration
Deployment isn’t just about loading software onto a robot; it’s about integrating that robot into an existing operational ecosystem. This process demands careful planning, ensuring compatibility with existing infrastructure and adherence to safety protocols. A critical step involves strong network configuration, especially for fleets of robots communicating simultaneously. For instance, at a major e-commerce fulfillment center, deploying 50 new picking robots required not only software installation but also smooth integration with warehouse management systems (WMS) and inventory control, a project that took 6.5 months to complete, according to their internal reports. This highlights the need for a holistic strategy, not just a technical one.
Overcoming Integration Hurdles
Integration often presents unexpected challenges, ranging from network latency to data format discrepancies. What most people overlook is the “human factor” — training staff to interact safely and efficiently with new robotic systems. Effective integration requires a deep understanding of both the robot’s capabilities and the environment it will operate in. One common hurdle is ensuring interoperability between different vendors’ hardware and software components; a robot arm from one manufacturer might not natively “speak” the same language as a vision system from another. This is where standardized communication protocols, like those facilitated by ROS, play a vital role in powering tomorrow’s machines. Without these standards, each integration becomes a bespoke engineering challenge.
The Future Evolution of Robotic Software
Think robotic software has peaked? Not even close. The next wave promises an even more unsettling level of autonomy, pushing machines beyond programmed tasks into genuinely adaptive roles. What most people miss is that this isn’t just about faster computation; it’s about fundamentally rethinking how robots perceive and interact with their environments, moving from predictable responses to nuanced, context-aware decisions. The real turning point will be in swarm intelligence, where decentralized control allows groups of robots to collaborate without a single point of failure. Imagine a thousand drones coordinating to map a disaster zone, each making independent decisions yet contributing to a collective goal. This shift, according to Dr. Anya Sharma, lead researcher at the Advanced Robotics Institute, will slash operational costs by an average of 37% in logistics within the next five years, making complex operations surprisingly efficient. Intuitive human-robot interfaces will also shed their clunky past, evolving beyond voice commands to anticipate human intent through gestures and even biometric feedback. We’re talking about robots that understand your unspoken needs, creating a partnership rather than a master-slave dynamic. This convergence with advanced AI, a topic extensively covered in discussions around how robotics and AI are converging, means software will become the ultimate translator between human desire and mechanical action. Could your next coworker be a machine that “gets” you? Some industry leaders, like Boston Dynamics CEO Robert Playter, predict that advanced cognitive architectures will enable robots to learn new, complex tasks from a single demonstration, drastically reducing programming times and opening doors to historic applications. This kind of progress hints at a future where practical AI applications are transforming industries at an accelerating pace.
The Evolving Frontier of Robotic Intelligence
The journey through the software solutions driving modern robotics reveals a landscape of continuous innovation. We’ve seen how foundational operating systems and middleware provide the backbone, while AI and machine learning infuse robots with perception, learning, and decision-making capabilities that were once the stuff of science fiction. Cloud robotics extends their reach, offering access to vast computational power and collective intelligence, yet this connectivity simultaneously introduces complex cybersecurity vulnerabilities that demand proactive and refined defenses.
Looking ahead, the convergence of these technologies promises even more profound transformations. The ethical frameworks for AI-driven autonomy will continue to evolve, alongside the technical advancements that make robots more intuitive, adaptable, and integrated into daily life. The challenge for developers, researchers, and policymakers alike will be to navigate this intricate ecosystem, ensuring that the intelligent core of robotics is built on principles of safety, transparency, and human benefit. The question isn’t just what robots can do, but how we will responsibly guide their ever-increasing capabilities.
Frequently Asked Questions About Robotic Software
- What is the difference between an industrial robot and a service robot in terms of software?
- Industrial robots often utilize highly specialized, deterministic software optimized for repetitive, high-precision tasks in controlled environments, often relying on proprietary programming languages. Service robots, conversely, typically feature more complex, adaptive software incorporating AI, machine learning, and natural language processing to interact with dynamic human environments and perform varied tasks, often built on open-source frameworks like ROS.
- How important is open-source software like ROS in robotics development?
- Open-source software like ROS (Robot Operating System) is critically important as it provides a flexible framework, standardized communication protocols, and a rich ecosystem of tools and libraries for robotics development. It significantly democratizes access to robotics, accelerates development cycles by promoting code reuse, and fosters a collaborative community that drives innovation across various applications.
- Can robotics software be updated remotely, and what are the risks?
- Yes, robotics software can be updated remotely, which offers significant advantages for maintenance and feature deployment across fleets of robots. remote updates carry risks such as potential security vulnerabilities during transmission, the possibility of bricking a robot if an update fails, and the challenge of ensuring compatibility across diverse hardware configurations, necessitating strong testing and secure protocols.
- What role does cybersecurity play in the reliability of autonomous robots?
- Cybersecurity plays a important role in the reliability of autonomous robots by protecting them from malicious attacks that could compromise their functionality, data integrity, or physical safety. A breach could lead to operational downtime, data theft, physical damage, or even endanger human lives, making secure software development, reliable authentication, and continuous vulnerability monitoring primary for trustworthy autonomous operation.
- How are low-code/no-code platforms impacting robotics software development?
- Low-code/no-code platforms are impacting robotics software development by making it more accessible to a broader range of users, including those without extensive programming expertise. These platforms allow for faster prototyping and deployment of robotic applications by simplifying complex coding tasks into visual drag-and-drop interfaces, potentially accelerating innovation and reducing development costs for certain applications.